
Robotics Industry cover — CNC machining services

Industry

CNC machining for robotics equipment

CNC milling · turning · EDM · grinding

Procurement context

Build repeatability into every robot interface.

Robotics components only work as a system when the bearing, motor, sensor and tooling interfaces agree. We use your assembly stack-up to plan machining datums, fit-sensitive features and the inspection evidence needed for prototype, qualification or repeat orders.

Revision-controlled
Drawing revision
Grade-confirmed
Material specification
Plan-agreed
Inspection scope
Schedule-reviewed
Delivery plan

CNC machining for robotics and automation: joint housings, brackets, end-effectors and sensor mounts. Define bearing fits, mounting datums, stiffness and cable clearances before selecting the machining and inspection route.

Applications

What we make for robotics

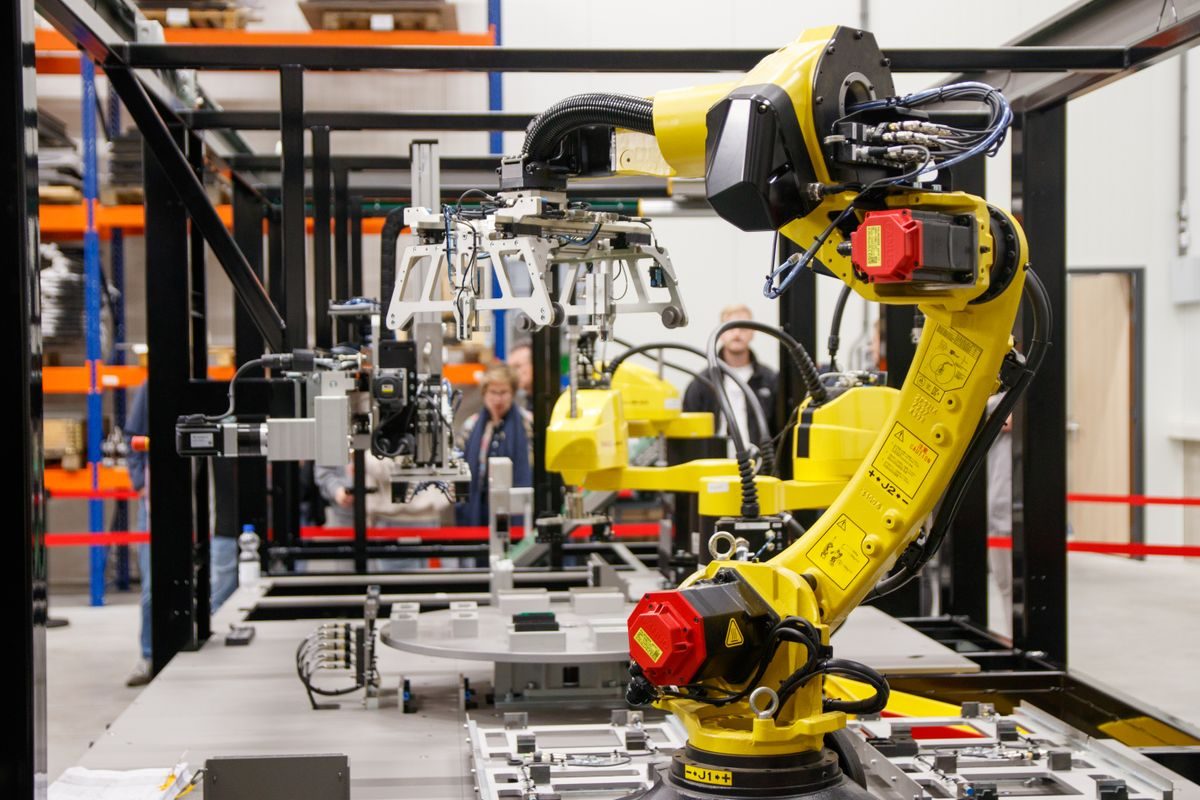
Robotic arm joint housing and linkage components

Robotic Arm Components

For arm links, joint housings and mounting brackets, we review bearing fits, datum faces and stiffness around the load path. Robotics assemblies amplify small interface errors into positioning, motion or service problems. The drawing review therefore links the part back to the joint, drive, sensor or tooling it supports.

Before release, confirm the primary datum scheme and the interfaces that transfer load or positioning into the next assembly.

ROV thruster housing and underwater manipulator arm

Underwater ROV & AUV

For underwater vehicles, we focus on sealed interfaces, corrosion exposure, pressure-boundary features and serviceable assembly details. Robotics assemblies amplify small interface errors into positioning, motion or service problems. The drawing review therefore links the part back to the joint, drive, sensor or tooling it supports.

The operating environment is converted into a practical review of materials, surfaces, sealing and handling before the route is released.

Cobot gripper fingers and quick-change tooling adapter

End-Effectors & Cobot Tooling

For grippers, tool changers and cobot end effectors, we align repeatable mounting interfaces, gripping surfaces and cable-clearance features. Robotics assemblies amplify small interface errors into positioning, motion or service problems. The drawing review therefore links the part back to the joint, drive, sensor or tooling it supports.

We identify the features that must align with adjacent electronics, fixtures or enclosures and define how they will be checked.

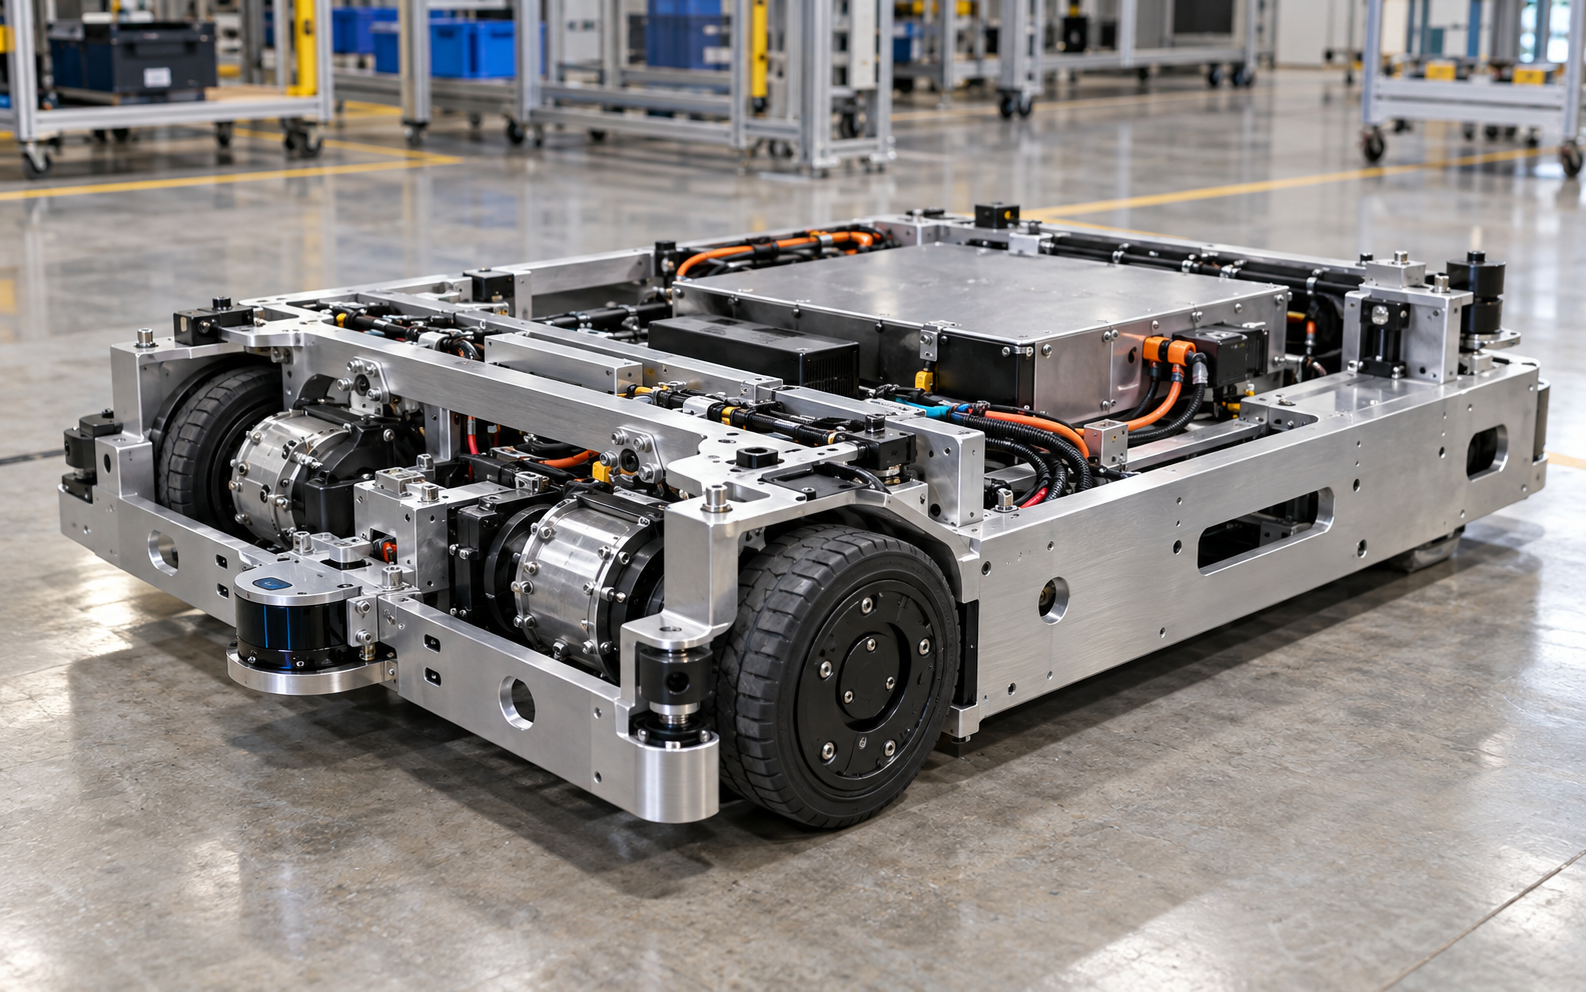
AGV chassis components and wheel assembly

AGV & AMR Chassis

For mobile-robot frames, we coordinate wheel and motor mounts, battery clearances, sensor locations and assembly datums. Robotics assemblies amplify small interface errors into positioning, motion or service problems. The drawing review therefore links the part back to the joint, drive, sensor or tooling it supports.

The review also covers installation access, tolerance build-up and the dimensions most likely to affect field assembly.

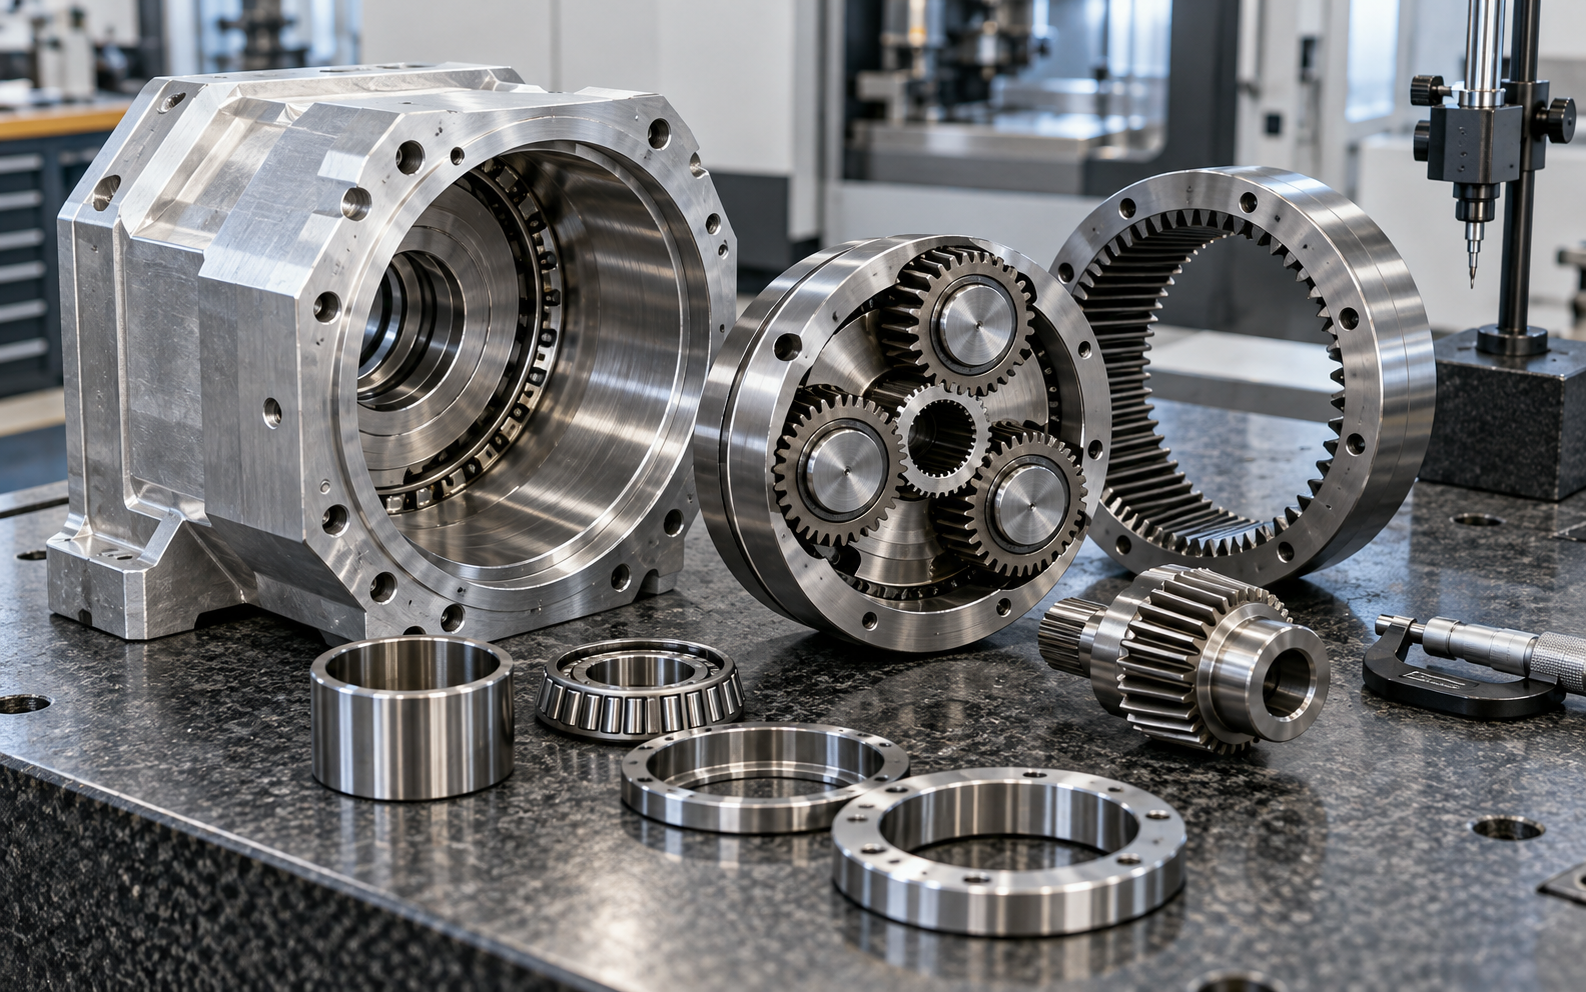
Precision planetary gear reducer components

Planetary Gear Reducers

For reducer housings and carriers, we control bearing seats, gear-center relationships, runout-sensitive features and inspection references. Robotics assemblies amplify small interface errors into positioning, motion or service problems. The drawing review therefore links the part back to the joint, drive, sensor or tooling it supports.

We agree which contact areas, interfaces and visible surfaces need focused process control and order-specific inspection evidence.

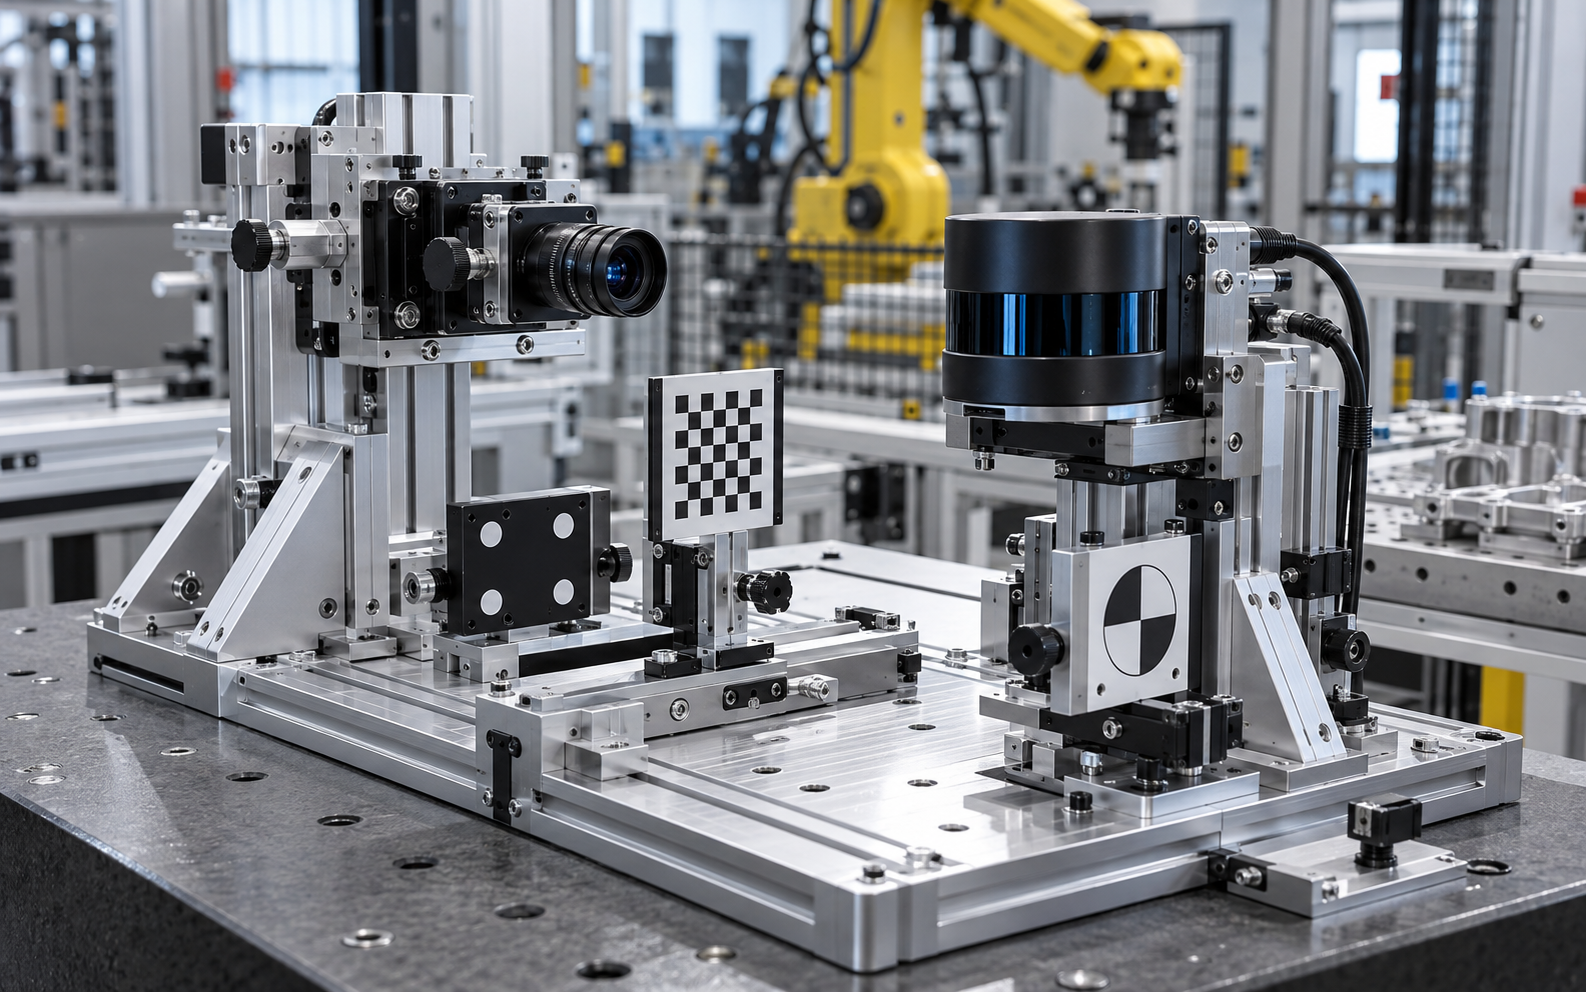
LIDAR and vision sensor mounting bracket

Vision & LIDAR Sensor Mounts

For vision and LIDAR mounts, we protect optical datums, field-of-view alignment, thermal stability and practical cable routing. Robotics assemblies amplify small interface errors into positioning, motion or service problems. The drawing review therefore links the part back to the joint, drive, sensor or tooling it supports.

The final review links the critical geometry to a workable machining sequence, measurement approach and delivery documentation scope.

How we work

Materials, tolerances, collaboration

CNC machining for robotics and automation: joint housings, brackets, end-effectors and sensor mounts. Define bearing fits, mounting datums, stiffness and cable clearances before selecting the machining and inspection route.

Which components can be reviewed?

Tecpreva reviews revision-controlled drawings for joint housings, brackets, end-effectors and sensor mounts. Geometry, material, volume and acceptance criteria determine project suitability; the industry label alone is not a qualification.

Material and finish selection

Consider aluminum for weight-sensitive structures, steel for wear-loaded features and engineering plastics for insulation. Specify the exact grade, condition, finish standard, coating thickness and protected surfaces. Do not substitute a material or change a functional surface without approval.

What should the RFQ include?

Send the 2D drawing and STEP model, revision, quantities, critical features, destination and inspection plan. For this application, focus on bearing fits, mounting datums, stiffness and cable clearances. Identify any special testing, cleanliness or customer documentation requirements separately.

How is sample-to-production consistency controlled?

Agree the first-article acceptance process, datum strategy, inspection coverage and batch identification. Use approved drawings and samples as controlled references. Confirm any certification, regulatory, leak-test or performance-test requirement before accepting the order.

Drawing review

Discuss Robotics machining requirements

Send the current drawing revision, STEP model, material grade, quantity and inspection scope. Engineering sends an initial response within one business day and confirms manufacturing assumptions after drawing review.

Request a manufacturing review